Specifications
Product Specification
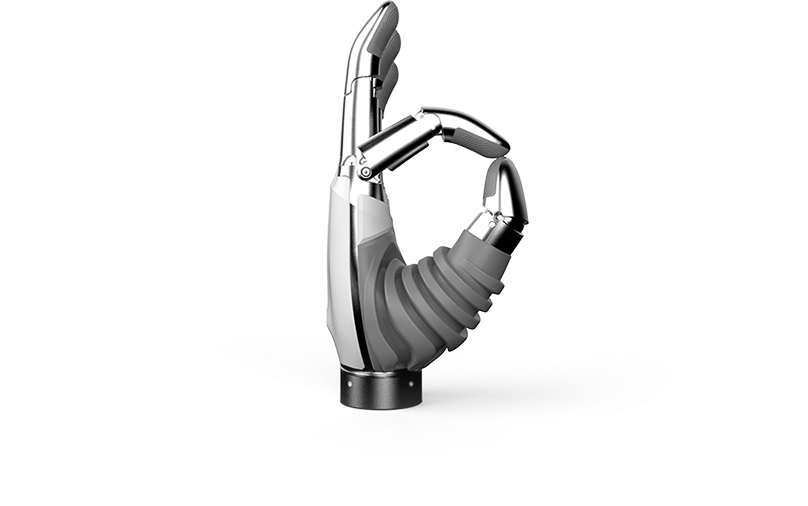
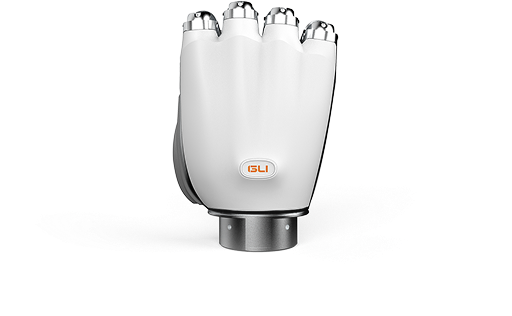
Basic
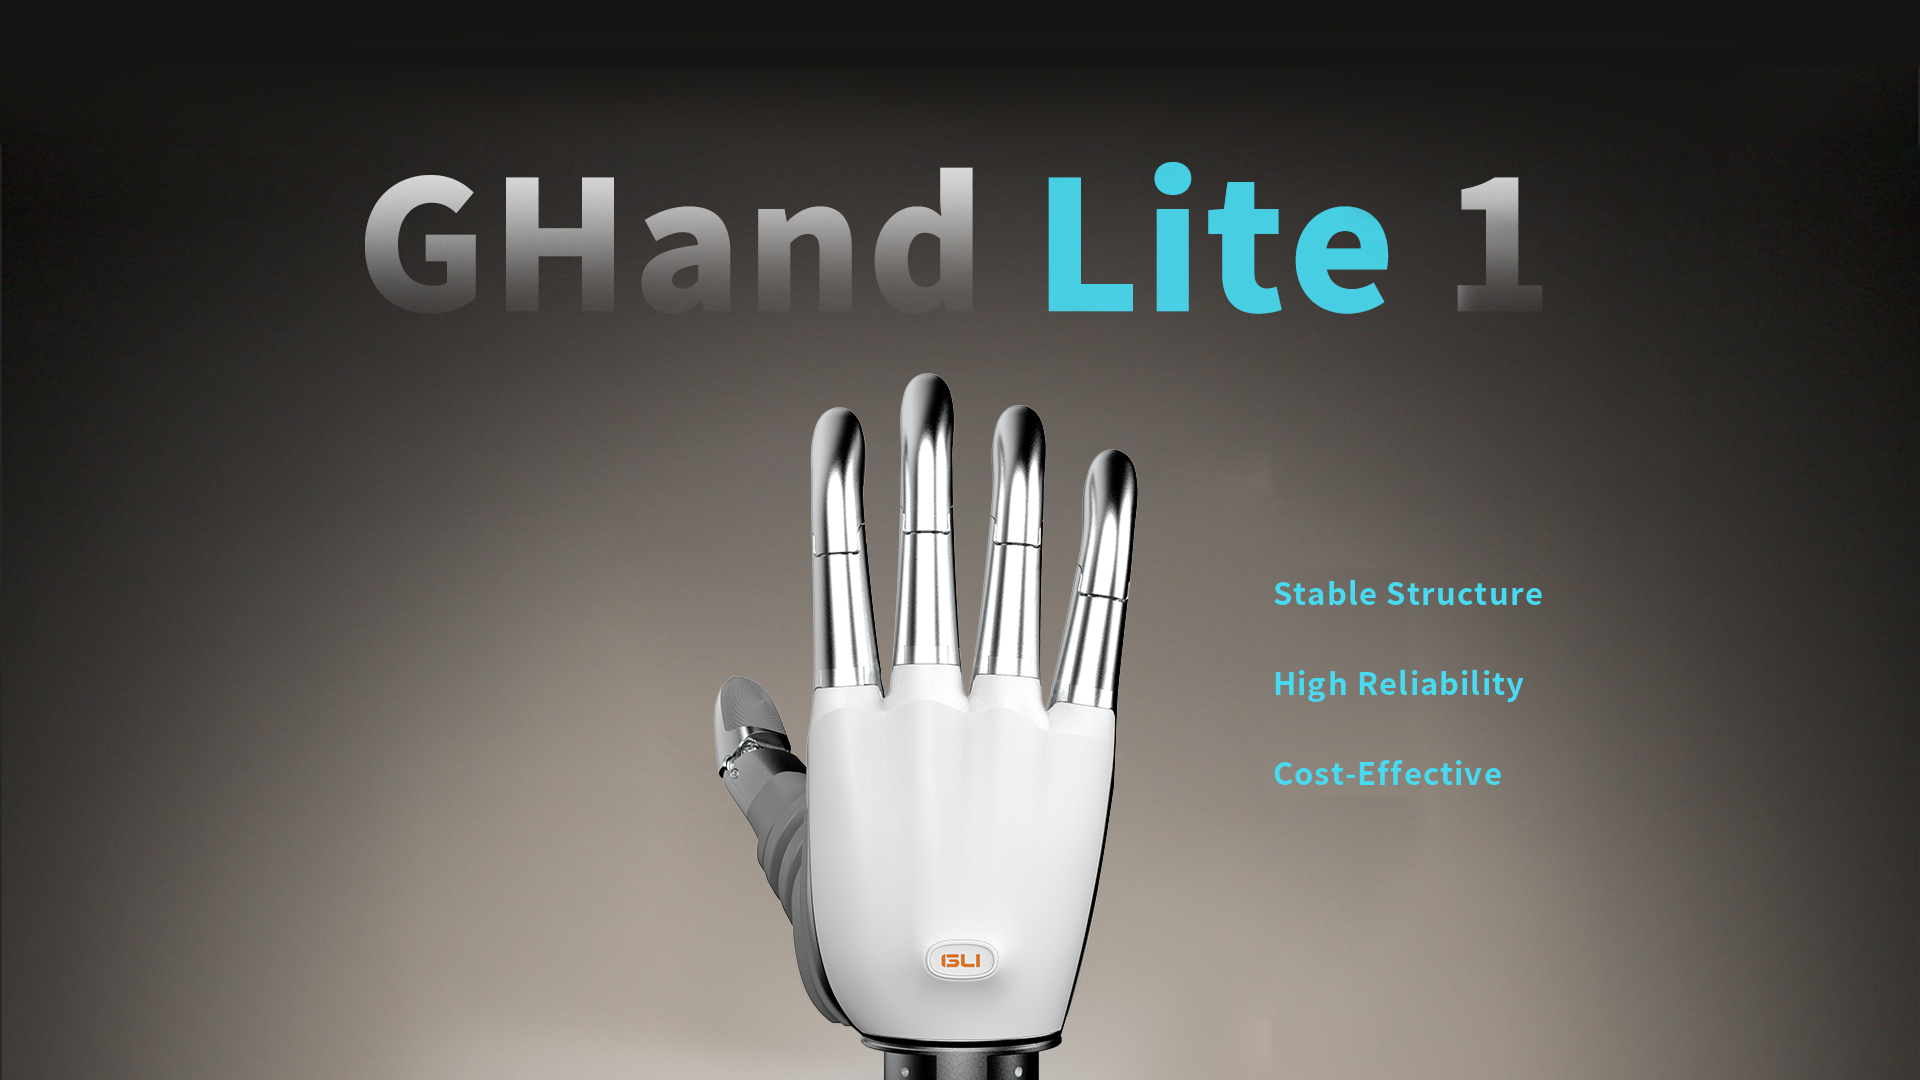
ModelL1-6A11D-S01
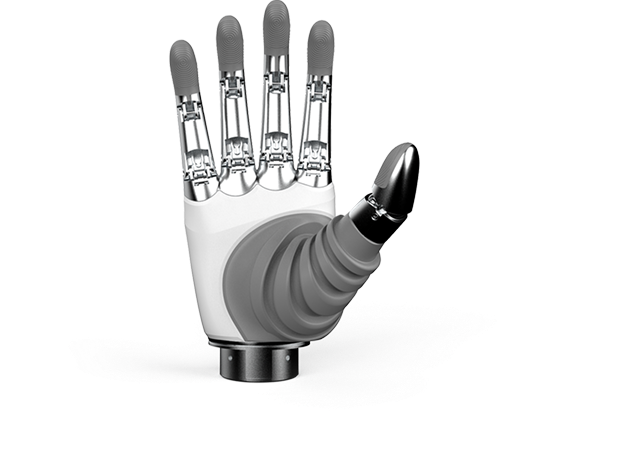
Dimensions162 mm × 73.5 mm × 37 mm
Weight< 420 g
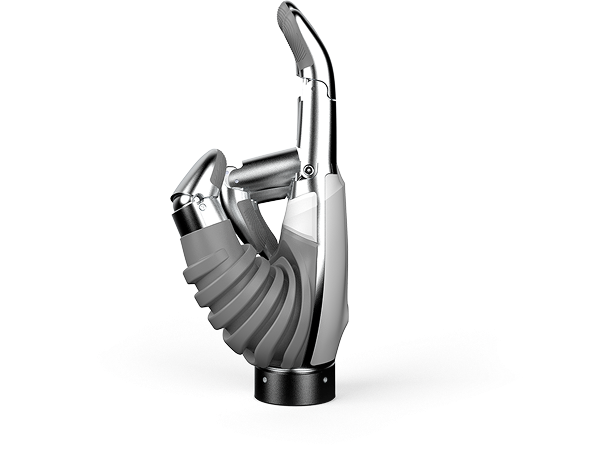
Degrees of freedom11 (6 active + 5 passive)
DOF allocationThumb: 2 active + 1 passive
Index: 1 active + 1 passive
Middle: 1 active + 1 passive
Ring: 1 active + 1 passive
Little: 1 active + 1 passive
Motor typeBrushless coreless motor
StructureLinkage + worm gear
Max grip force (whole hand)50 N
Max fingertip force (single finger)20 N
Payload20 kg
Closing time≤ 0.65 s
Repeatability0.2 mm
Sensing
SensorsTactile sensor (optional), temperature sensor, position sensor
Fault detectionOver-current, stall, over-voltage, under-voltage, over-temperature and interference detection
Operating voltageDC 24 V – 60 V
CommunicationEtherCAT / CAN FD / RS485
SDK languagesPython / C++ / ROS2
Software featuresPosition, velocity and torque control; motion sequences; GUI control; tactile force control; virtual simulation; gesture control
Control modesTriple-loop PID control; velocity, torque, position and hybrid force-position control; adaptive grasping
Operating systemsWindows / Linux / macOS
Ecosystem compatibilityCompatible with mainstream humanoid robots, robotic arms, data-collection gloves and VR headsets;
supported simulators: Isaac Sim, MuJoCo, Gazebo
Operating temperature-20 °C – 50 °C
Motor lifetime> 2000 h (2 million cycles)
Full-hand open/close (no load)≥ 1,000,000 cycles